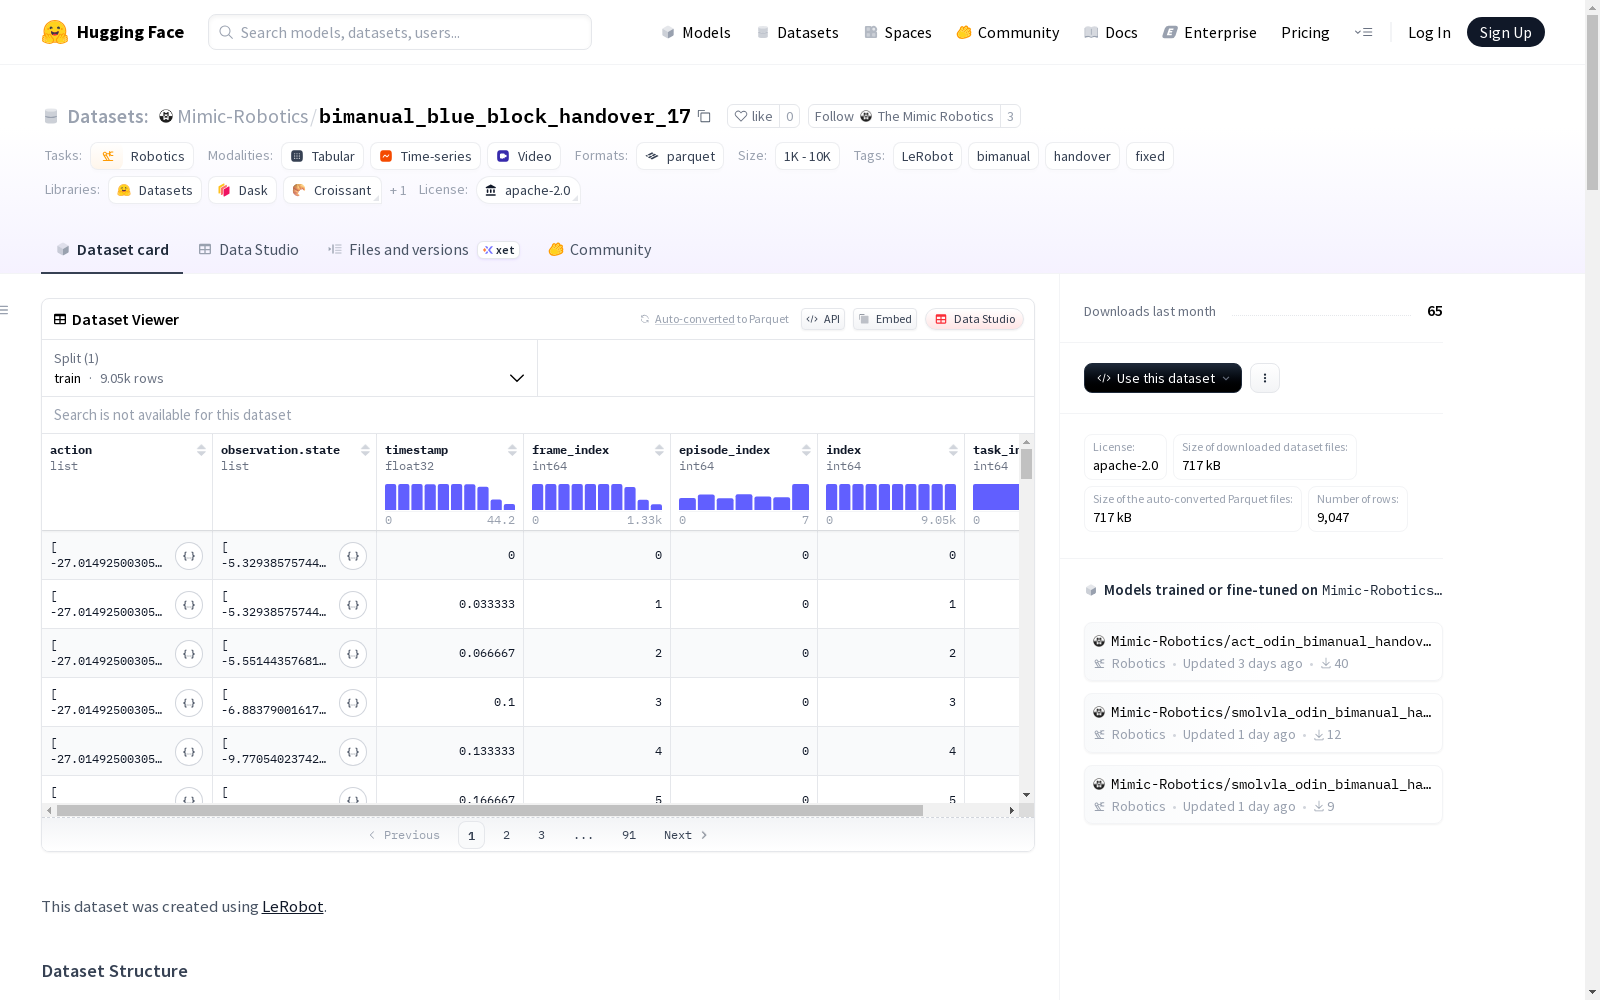
bimanual_blue_block_handover_17
收藏资源简介:
这是一个关于机器人操作的数据集,包含双臂机器人(bi_so101_follower)执行的任务数据。数据集共有8个剧集,9047帧,24个视频文件,分为1个块,每块1000帧。数据集的帧率是30fps,支持训练集分割。数据集中的特征包括动作和观察状态,动作特征包括双臂的多个关节位置和抓握器的位置,观察状态特征与动作特征相同。此外,还包括了右腕、左腕和顶部Realsense相机的视频信息。
This is a robotic manipulation dataset containing task data executed by the dual-arm robot (bi_so101_follower). The dataset includes 8 episodes, 9047 frames and 24 video files, divided into 1 chunk with 1000 frames per chunk. The frame rate of the dataset is 30fps, and training set splitting is supported. The features in the dataset cover actions and observation states: the action features include multiple joint positions of both arms and the positions of the grippers, while the observation state features are identical to the action features. Additionally, video information from the right wrist, left wrist and top Realsense camera is also included.
数据集概述
基本信息
- 数据集名称: bimanual_blue_block_handover_17
- 许可证: Apache-2.0
- 任务类别: 机器人技术
- 标签: LeRobot、双手操作、交接任务、固定配置
数据集规模
- 总任务数: 1
- 总片段数: 8
- 总帧数: 9047
- 总视频数: 24
- 数据块数: 1
- 块大小: 1000
- 帧率: 30 FPS
- 训练集划分: 0:8
数据结构
数据文件路径
- 数据文件:
data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet - 视频文件:
videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4
特征描述
动作特征
- 数据类型: float32
- 维度: [12]
- 关节位置:
- 左肩平移位置
- 左肩抬升位置
- 左肘弯曲位置
- 左腕弯曲位置
- 左腕旋转位置
- 左夹爪位置
- 右肩平移位置
- 右肩抬升位置
- 右肘弯曲位置
- 右腕弯曲位置
- 右腕旋转位置
- 右夹爪位置
观测状态
- 数据类型: float32
- 维度: [12]
- 关节位置(与动作特征相同)
图像观测
右手腕摄像头:
- 数据类型: 视频
- 分辨率: 480×640×3
- 编码: AV1
- 像素格式: yuv420p
- 非深度图
左手腕摄像头:
- 数据类型: 视频
- 分辨率: 480×640×3
- 编码: AV1
- 像素格式: yuv420p
- 非深度图
顶部RealSense摄像头:
- 数据类型: 视频
- 分辨率: 480×640×3
- 编码: AV1
- 像素格式: yuv420p
- 非深度图
元数据
- 时间戳: float32[1]
- 帧索引: int64[1]
- 片段索引: int64[1]
- 索引: int64[1]
- 任务索引: int64[1]
技术信息
- 代码库版本: v2.1
- 机器人类型: bi_so101_follower
- 视频属性: 无音频,30 FPS,3通道