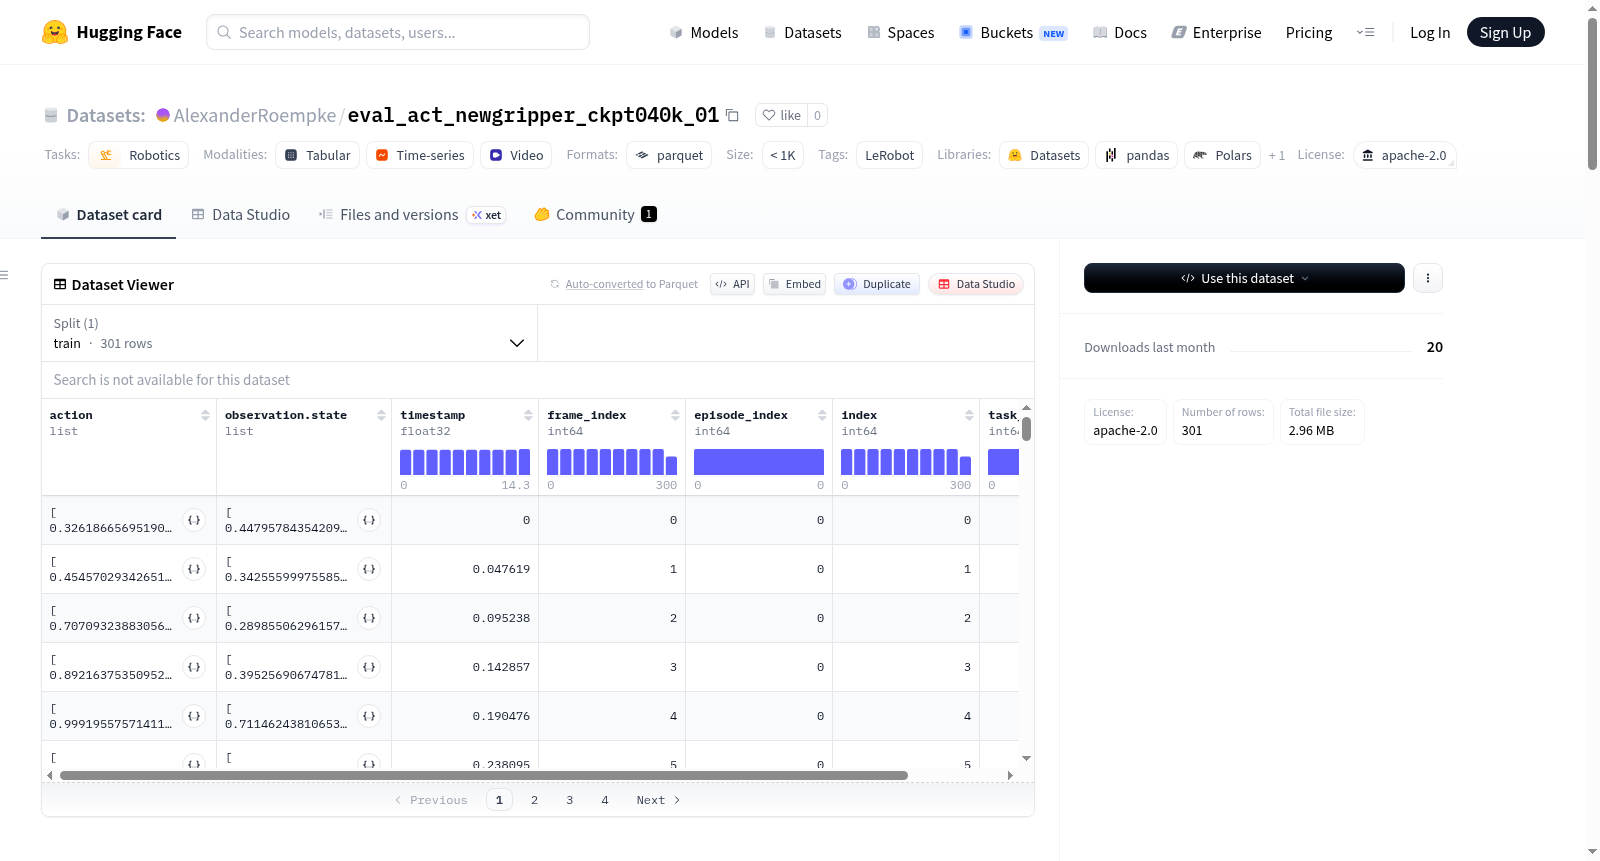
eval_act_newgripper_ckpt040k_01
收藏资源简介:
该数据集由LeRobot创建,采用apache-2.0许可证,属于机器人学领域。数据集包含5个总片段,1541帧,1个总任务,数据文件大小为100MB,视频文件大小为200MB,帧率为21fps。数据以parquet格式存储,视频以mp4格式存储。数据集结构包括动作和观察状态,两个摄像头的图像数据,以及时间戳、帧索引、片段索引、索引和任务索引等特征。动作和观察状态均包含7个浮点型位置数据。图像数据分辨率为480x640,3通道,视频编码为av1,像素格式为yuv420p,无音频。数据集适用于机器人控制和视觉任务的研究。
This dataset was developed by LeRobot, distributed under the Apache-2.0 license, and falls within the field of robotics. It consists of 5 total segments, 1541 frames, and covers 1 overall task. The total size of the data files is 100 MB, while the video files amount to 200 MB, with a frame rate of 21 fps. The tabular data is stored in Parquet format, and the videos are in MP4 format. The dataset structure includes actions, observation states, image data from two cameras, as well as features such as timestamps, frame indices, segment indices, indexes, and task indices. Both actions and observation states contain 7 floating-point position values. The image data has a resolution of 480×640 with 3 channels; the videos are encoded with AV1, use the YUV420p pixel format, and have no audio tracks. This dataset is applicable to research on robot control and visual tasks.
数据集概述:eval_act_newgripper_ckpt040k_01
该数据集是一个面向机器人(Robotics)任务的数据集,基于 LeRobot 框架创建,采用 Apache-2.0 许可证。
基本信息
- 数据集名称:
eval_act_newgripper_ckpt040k_01 - 机器人类型:
ned2 - 总集数(Episodes): 1
- 总帧数(Frames): 301
- 总任务数(Tasks): 1
- 数据文件大小: 100 MB
- 视频文件大小: 200 MB
- 帧率(FPS): 21
数据集结构
- 代码库版本: v3.0
- 分块大小(Chunks Size): 1000
- 数据划分: 仅包含训练集(train),划分比例为
0:1(全部数据用于训练)。 - 数据路径格式:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频路径格式:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
主要特征(Features)
数据集包含以下关键字段,各字段具体信息如下:
| 特征名称 | 数据类型 | 形状(Shape) | 字段说明 |
|---|---|---|---|
action |
float32 | [7] | 机器人动作:包括6个关节位置(base_to_arm.pos, arm_to_elbow.pos, elbow_to_forearm.pos, forearm_to_hand.pos, hand_to_shoulder.pos, shoulder_to_wrist.pos)和1个夹爪位置(gripper.pos) |
observation.state |
float32 | [7] | 机器人的观测状态:字段名称与 action 完全一致,即7维的关节位置与夹爪位置 |
observation.images.camera1 |
video | [480, 640, 3] | 来自摄像头1的视频流:分辨率480x640,3通道(RGB),编码格式为AV1,帧率21 FPS,非深度图 |
observation.images.camera2 |
video | [480, 640, 3] | 来自摄像头2的视频流:参数与camera1完全一致 |
timestamp |
float32 | [1] | 时间戳 |
frame_index |
int64 | [1] | 帧索引 |
episode_index |
int64 | [1] | 集数索引 |
index |
int64 | [1] | 整体索引 |
task_index |
int64 | [1] | 任务索引 |