RGB-Event-LiDAR Dataset
收藏资源简介:
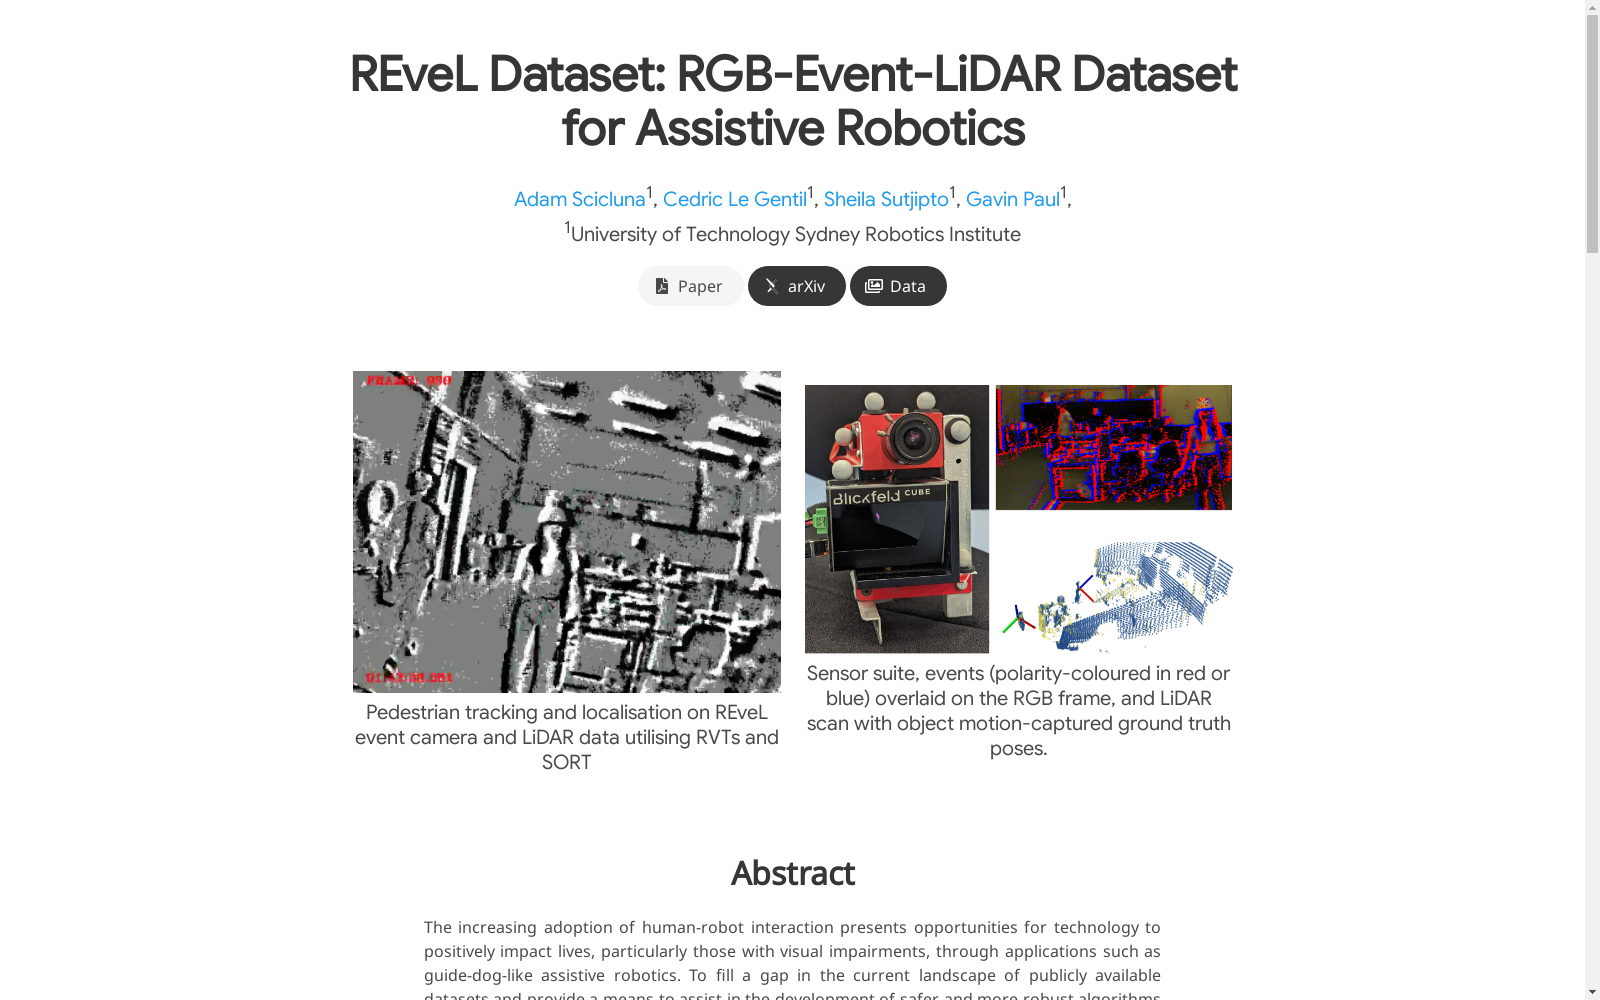
RGB-Event-LiDAR数据集由悉尼科技大学机器人研究所创建,用于辅助机器人系统的感知和决策。该数据集包含室内环境中两个移动人物的RGB图像、事件数据、点云和IMU数据,总计约774百万个事件和22000张RGB图像。数据集通过复杂的传感器套件和Vicon运动捕捉系统收集,确保了数据的精确性和多样性。创建过程中,数据集经过精细的校准和标记,以支持3D对象检测和空间姿态估计。该数据集主要应用于辅助机器人领域,特别是模拟导盲犬的智能不服从行为,以提高用户的安全性和机器人的鲁棒性。
The RGB-Event-LiDAR dataset was developed by the Robotics Institute of the University of Technology Sydney to facilitate perception and decision-making for robotic systems. This dataset includes RGB images, event data, point clouds and IMU data of two moving pedestrians in indoor environments, with a total of approximately 774 million events and 22,000 RGB images. Collected using a sophisticated sensor suite and the Vicon motion capture system, the dataset guarantees data accuracy and diversity. During its development, the dataset underwent meticulous calibration and annotation to support 3D object detection and spatial pose estimation. This dataset is primarily applied in the field of assistive robotics, specifically for simulating the intelligent disobedience behavior of guide dogs to improve user safety and enhance robotic robustness.