Tactile Functasets
收藏资源简介:
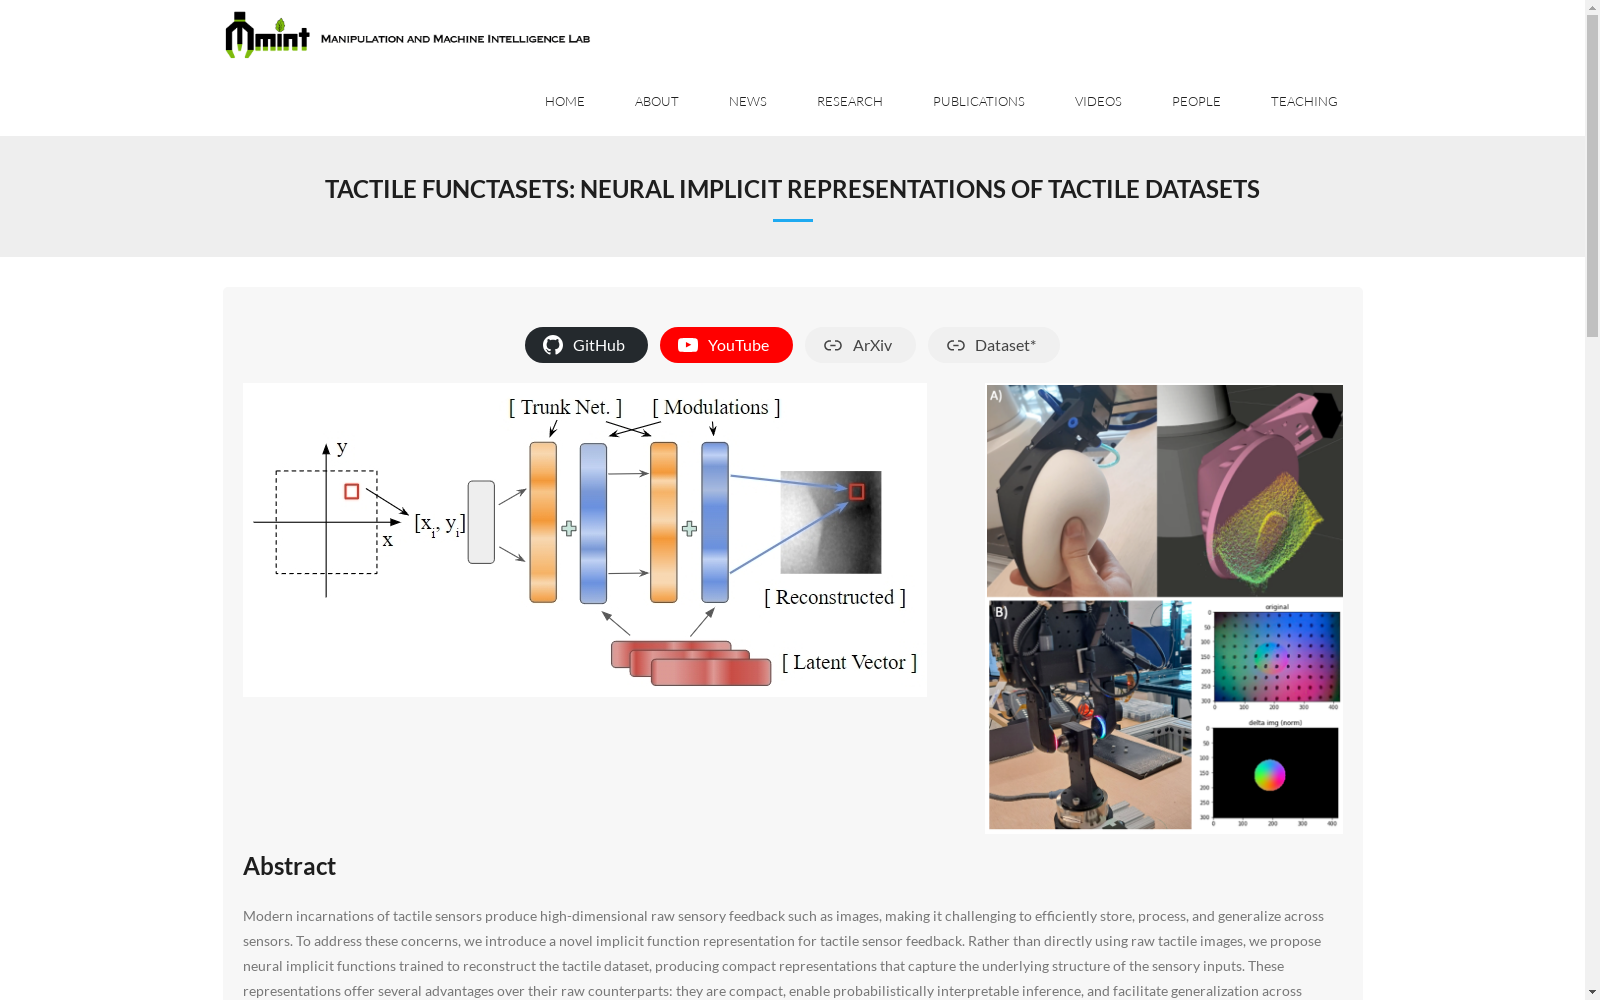
Tactile Functasets是由密歇根大学开发的一个用于触觉传感器数据的高效存储和处理的数据集。该数据集通过神经隐式函数来重建触觉传感器的高维数据,生成紧凑的表示形式,从而解决了传统触觉图像数据存储和处理的高成本问题。数据集的创建过程涉及训练神经网络以捕捉触觉数据的底层结构,并使用共享的基础网络和调制向量来表示多个触觉输入。该数据集主要应用于机器人操作中的物体姿态估计任务,旨在提高触觉传感在机器人领域的实时性能和传感器灵活性。
Tactile Functasets is a dataset developed by the University of Michigan for efficient storage and processing of tactile sensor data. This dataset reconstructs high-dimensional tactile sensor data via neural implicit functions to generate compact representations, thereby addressing the high-cost issues in storage and processing of traditional tactile image data. The creation of this dataset involves training neural networks to capture the underlying structure of tactile data, and using a shared base network and modulation vectors to represent multiple tactile inputs. This dataset is primarily applied to object pose estimation tasks in robotic manipulation, aiming to improve the real-time performance and sensor flexibility of tactile sensing in the robotics field.