omx_bilateral_force_v2
收藏资源简介:
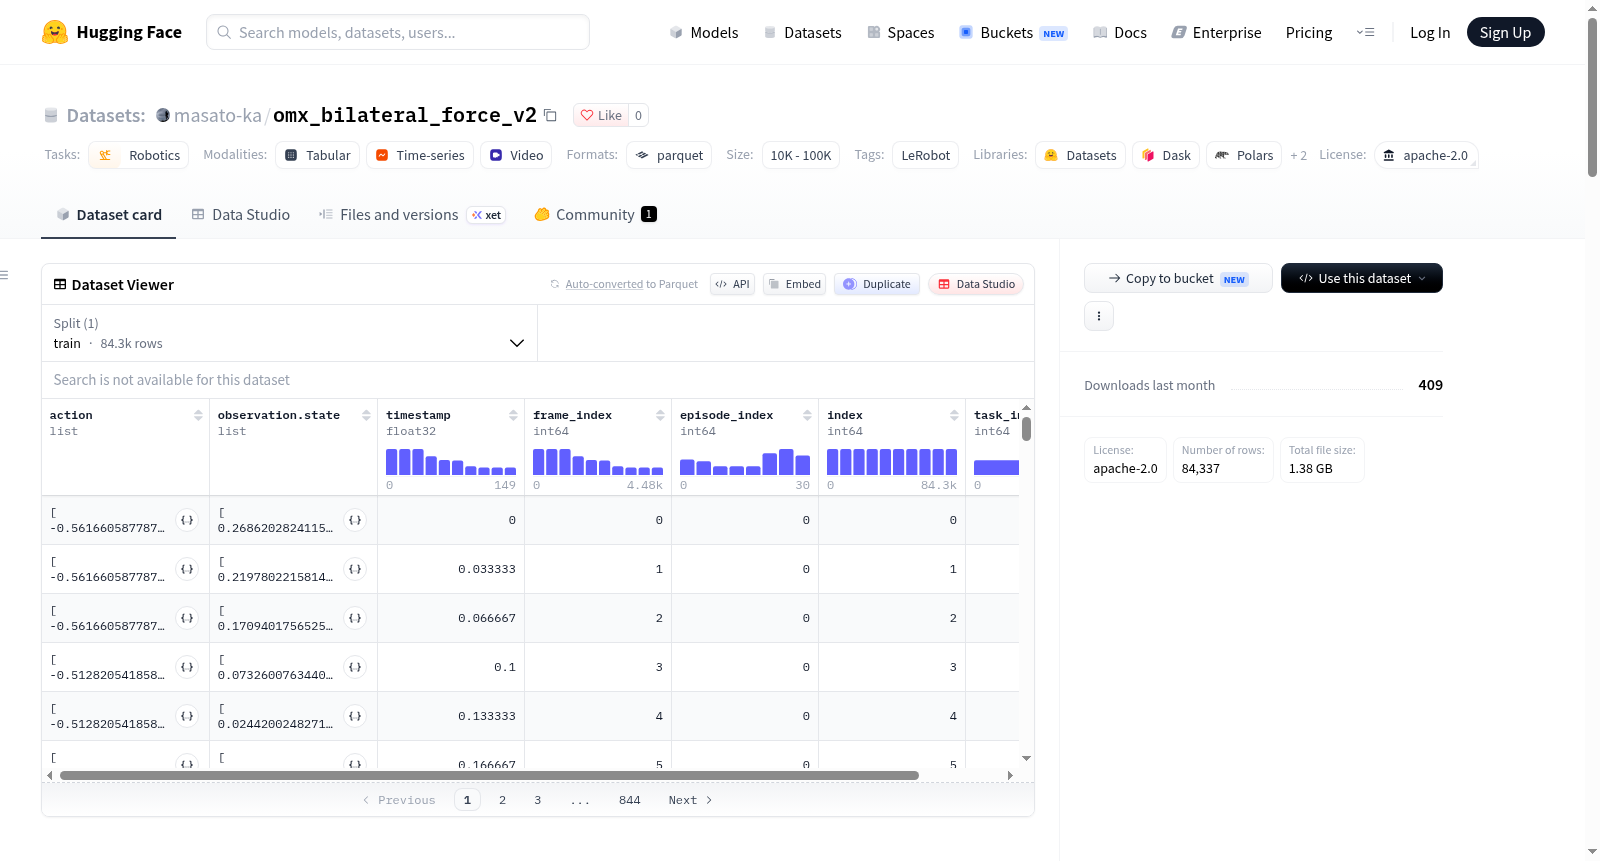
该数据集由LeRobot框架创建,名为omx_bilateral_force_v2,是一个面向机器人操作学习的数据集。数据集包含28个episode,总计70882帧,覆盖3个不同任务。机器人类型为omx_follower。数据特征包括:动作(action)为6维浮点向量,对应6个关节位置(shoulder_pan, shoulder_lift, elbow_flex, wrist_flex, wrist_roll, gripper);状态(observation.state)为11维浮点向量,包含上述6个关节位置以及5个关节力信息(force.shoulder_pan等);视觉观测(observation.images.overhead)为来自顶视图的RGB视频,分辨率480x640,帧率30fps,编码为AV1;此外还有时间戳、帧索引、episode索引、任务索引等辅助字段。数据以parquet格式存储,视频以mp4格式存储。数据集可用于机器人模仿学习、强化学习、力控制等研究。
This dataset is created by the LeRobot framework, named omx_bilateral_force_v2, and is a dataset for robot manipulation learning. It contains 28 episodes with a total of 70882 frames, covering 3 different tasks. The robot type is omx_follower. Data features include: action (6-dimensional float vector corresponding to 6 joint positions: shoulder_pan, shoulder_lift, elbow_flex, wrist_flex, wrist_roll, gripper); observation.state (11-dimensional float vector containing the above 6 joint positions and 5 joint force information such as force.shoulder_pan); observation.images.overhead (RGB video from an overhead view, resolution 480x640, frame rate 30fps, encoded with AV1); additionally, auxiliary fields such as timestamps, frame index, episode index, and task index are included. The data is stored in parquet format, and videos are stored in mp4 format. The dataset can be used for research in robot imitation learning, reinforcement learning, force control, etc.
- 数据集名称: omx_bilateral_force_v2
- 许可证: Apache 2.0
- 任务类别: 机器人技术(Robotics)
- 相关标签: LeRobot
- 创建工具: 该数据集通过 LeRobot 框架创建,并支持通过 Hugging Face 平台的可视化空间预览数据。
- 数据集结构:
- 代码版本: v3.0
- 帧率: 每秒 30 帧
- 机器人类型: omx_follower
- 数据总量: 28 个任务片段,共 70882 帧,包含 3 个任务
- 数据文件大小: 约 100 MB(Parquet 格式),视频文件大小约 200 MB(MP4 格式)
- 数据划分: 训练集包含全部 28 个片段(splits: train: 0:28)
- 数据特征:
- 动作 (action): 包含 6 个关节位置指令,具体为肩部旋转、肩部升降、肘部弯曲、腕部弯曲、腕部旋转和夹爪位置。
- 观测状态 (observation.state): 包含 11 维数据,由 6 个关节位置和 5 个力传感器读数(肩部旋转、肩部升降、肘部弯曲、腕部弯曲、腕部旋转)组成。
- 图像观测 (observation.images.overhead): 提供俯视摄像头视频,分辨率为 480x640 像素,带 RGB 三通道,采用 AV1 编码,帧率 30 fps。
- 时间戳 (timestamp): 记录每帧的时间戳。
- 索引信息: 包括帧索引、片段索引、全局索引和任务索引。
- 数据格式: 数据以 Parquet 文件存储,路径为
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet;视频以 MP4 文件存储,路径为videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4。 - 引用信息: 目前缺少引用论文或相关文献条目(标记为“More Information Needed”),且首页和论文信息尚未提供。