HyeonseokE/SO101-cap_pnp_baseline_10fps_80epi
收藏资源简介:
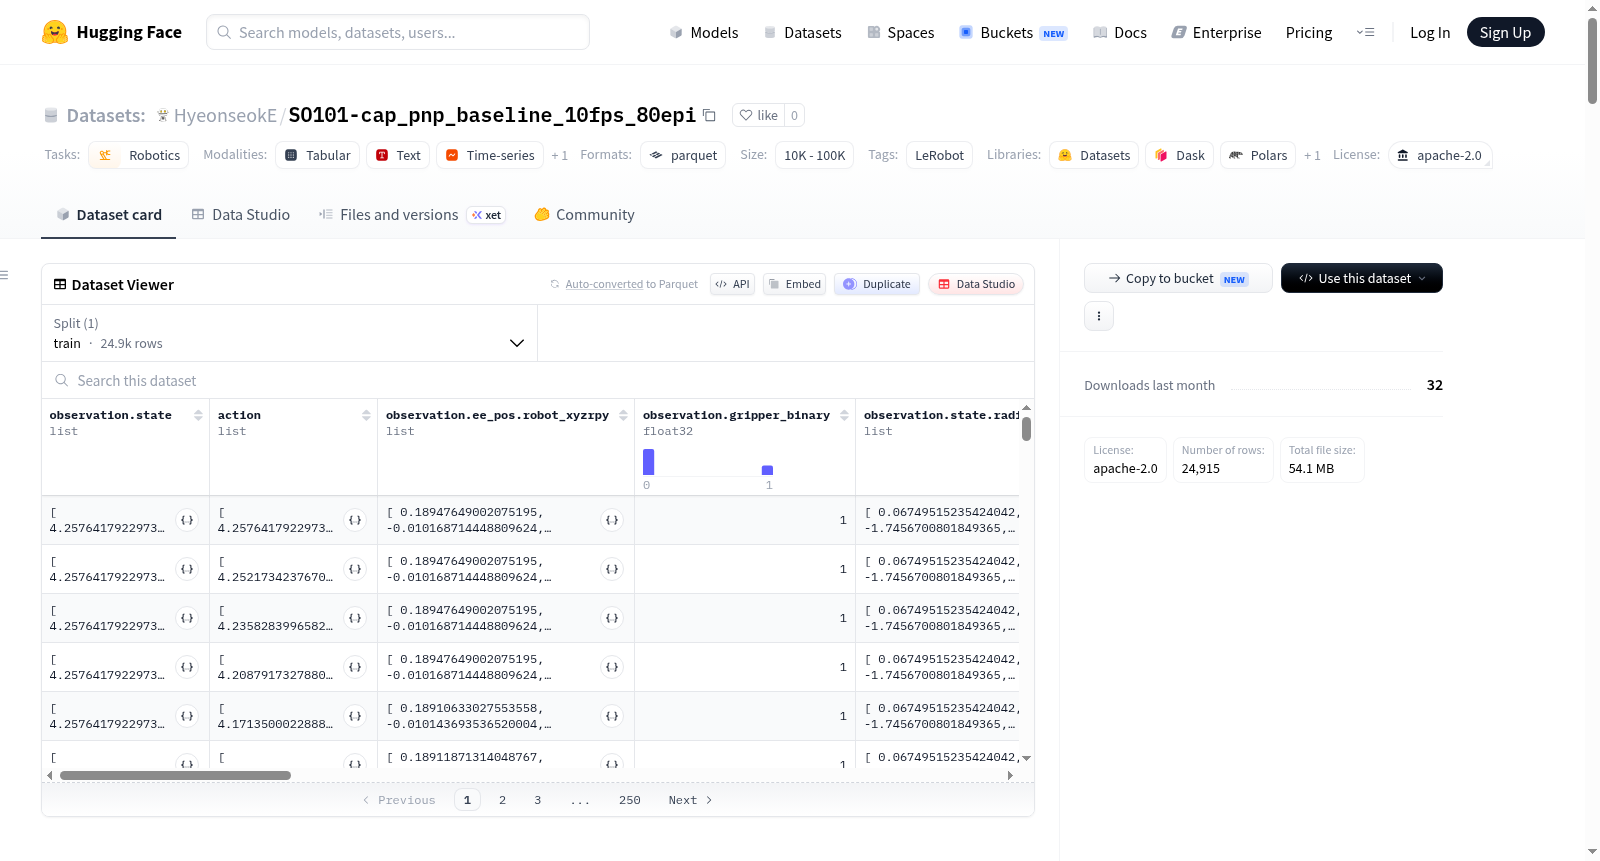
该数据集是一个用于机器人技术的数据集,通过LeRobot工具创建。数据集包含80个训练片段,总计24,915帧,采样率为10fps。数据记录了SO101跟随者机器人的状态信息,包括6个关节位置(如肩部平移、肩部提升、肘部弯曲等)、动作命令、顶部和左手腕视角的图像(分辨率480x640,视频编码为av1,30fps)、末端执行器位置(XYZ坐标和RPY姿态)、夹持器状态、技能描述(如自然语言指令、验证问题、技能类型、进度和目标位置)以及子任务信息(如自然语言描述、对象名称和目标位置)。数据集结构以Parquet文件存储,总数据文件大小为100MB,视频文件大小为200MB。
This dataset is a robotics dataset created using the LeRobot tool. It contains 80 training episodes, totaling 24,915 frames with a sampling rate of 10fps. The data records the state of an SO101 follower robot, including 6 joint positions (e.g., shoulder pan, shoulder lift, elbow flex), action commands, images from top and left wrist perspectives (resolution 480x640, video codec av1, 30fps), end-effector positions (XYZ coordinates and RPY orientation), gripper status, skill descriptions (e.g., natural language instructions, verification questions, skill type, progress, and goal positions), and subtask information (e.g., natural language descriptions, object names, and target positions). The dataset is structured in Parquet files, with a total data file size of 100MB and video file size of 200MB.