ankile/square-01a-blind-r2-baseline-mining-shape-beta05
收藏资源简介:
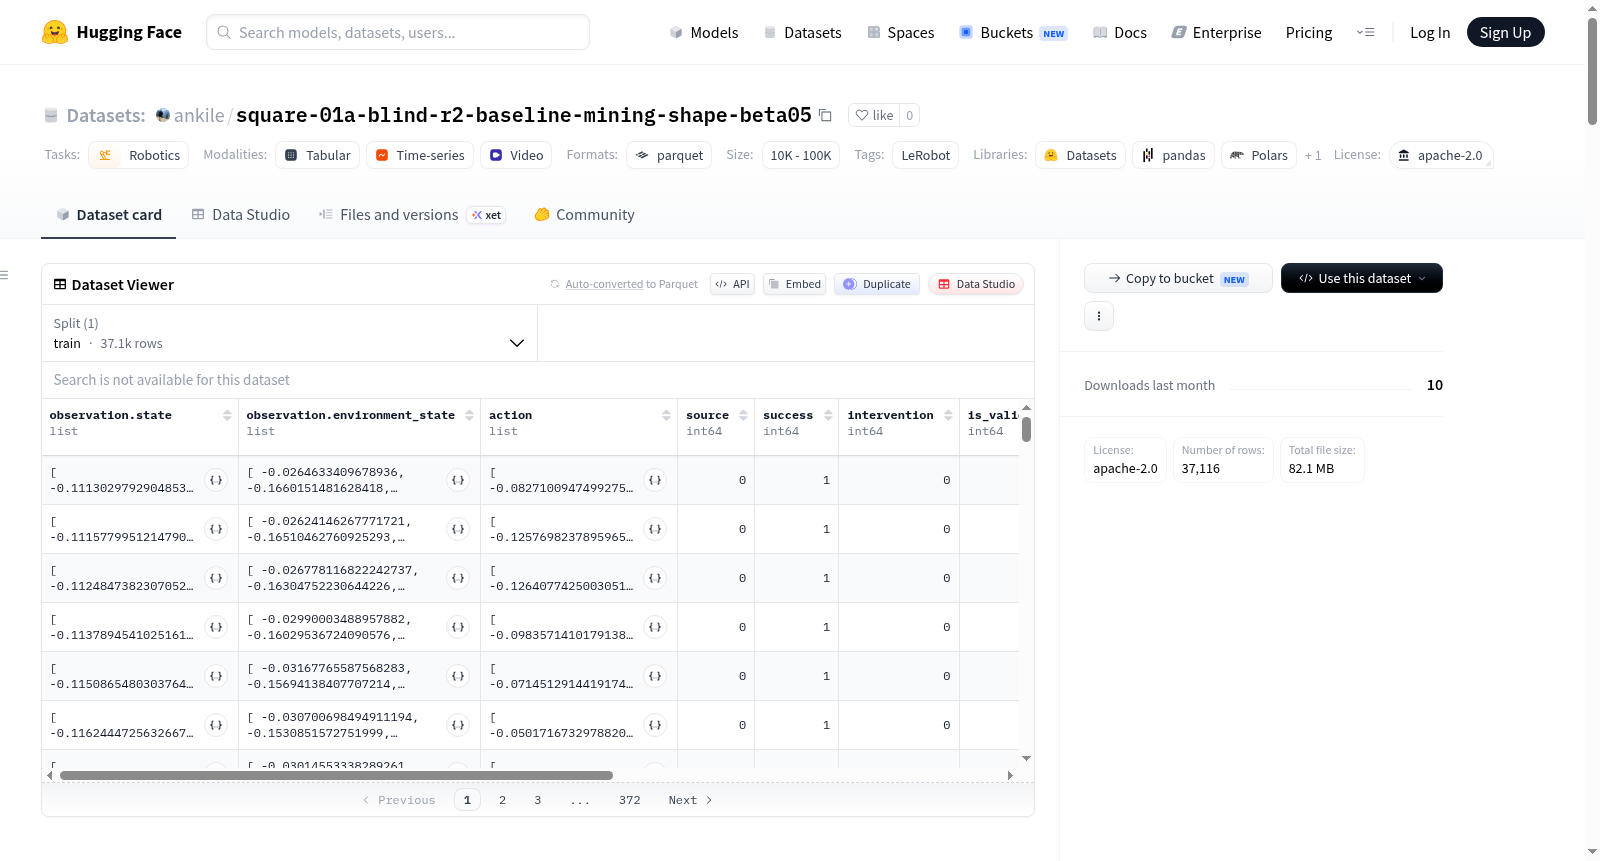
该数据集是一个机器人学数据集,使用LeRobot工具创建,专门针对Franka Emika Panda机器人。数据集包含206个总剧集和37116个总帧,以20帧每秒的速率记录,涵盖单个任务。数据结构包括观察状态(如末端执行器的位置和姿态)、环境状态(如螺母相对于末端执行器的位置和姿态)、动作(如增量运动和夹爪动作)、成功标志、干预标志、奖励、完成标志等特征。此外,数据集提供视频观察,包括代理视角和机器人手眼图像,分辨率为256x256像素,编码为h264。数据以Parquet文件格式存储,视频以MP4格式存储,总数据大小约100MB,视频大小约200MB。该数据集适用于机器人控制、强化学习和模仿学习等研究。
This dataset is a robotics dataset created using the LeRobot tool, specifically for the Franka Emika Panda robot. It contains a total of 206 episodes and 37,116 frames, recorded at 20 frames per second, covering a single task. The data structure includes features such as observation state (e.g., end-effector position and orientation), environment state (e.g., nut position relative to the end-effector), actions (e.g., delta movements and gripper actions), success flags, intervention flags, rewards, done flags, and more. Additionally, the dataset provides video observations, including agent-view and robot eye-in-hand images, with a resolution of 256x256 pixels and encoded in h264. The data is stored in Parquet file format, and videos are in MP4 format, with a total data size of approximately 100 MB and video size of 200 MB. This dataset is suitable for research in robot control, reinforcement learning, and imitation learning.