saipuneethgottam/pickplace_134cam_newdemos_20260526_161032_remapped
收藏资源简介:
该数据集是一个用于机器人拾取放置任务的数据集,使用LeRobot工具创建。数据集包含100个训练集episodes,总帧数为53178帧,帧率为30fps。数据格式为parquet文件,特征包括动作(6个关节位置:肩部平移、肩部提升、肘部弯曲、手腕弯曲、手腕旋转、夹爪位置)、观察图像(来自三个摄像头:camera1和camera2分辨率为1280x720,camera3分辨率为640x480,均为RGB视频)、观察状态(6个关节位置)、episode索引、帧索引、任务索引和时间戳。数据集专为so_follower机器人类型设计,视频文件使用AV1编码,总大小为200MB,数据文件大小为100MB。
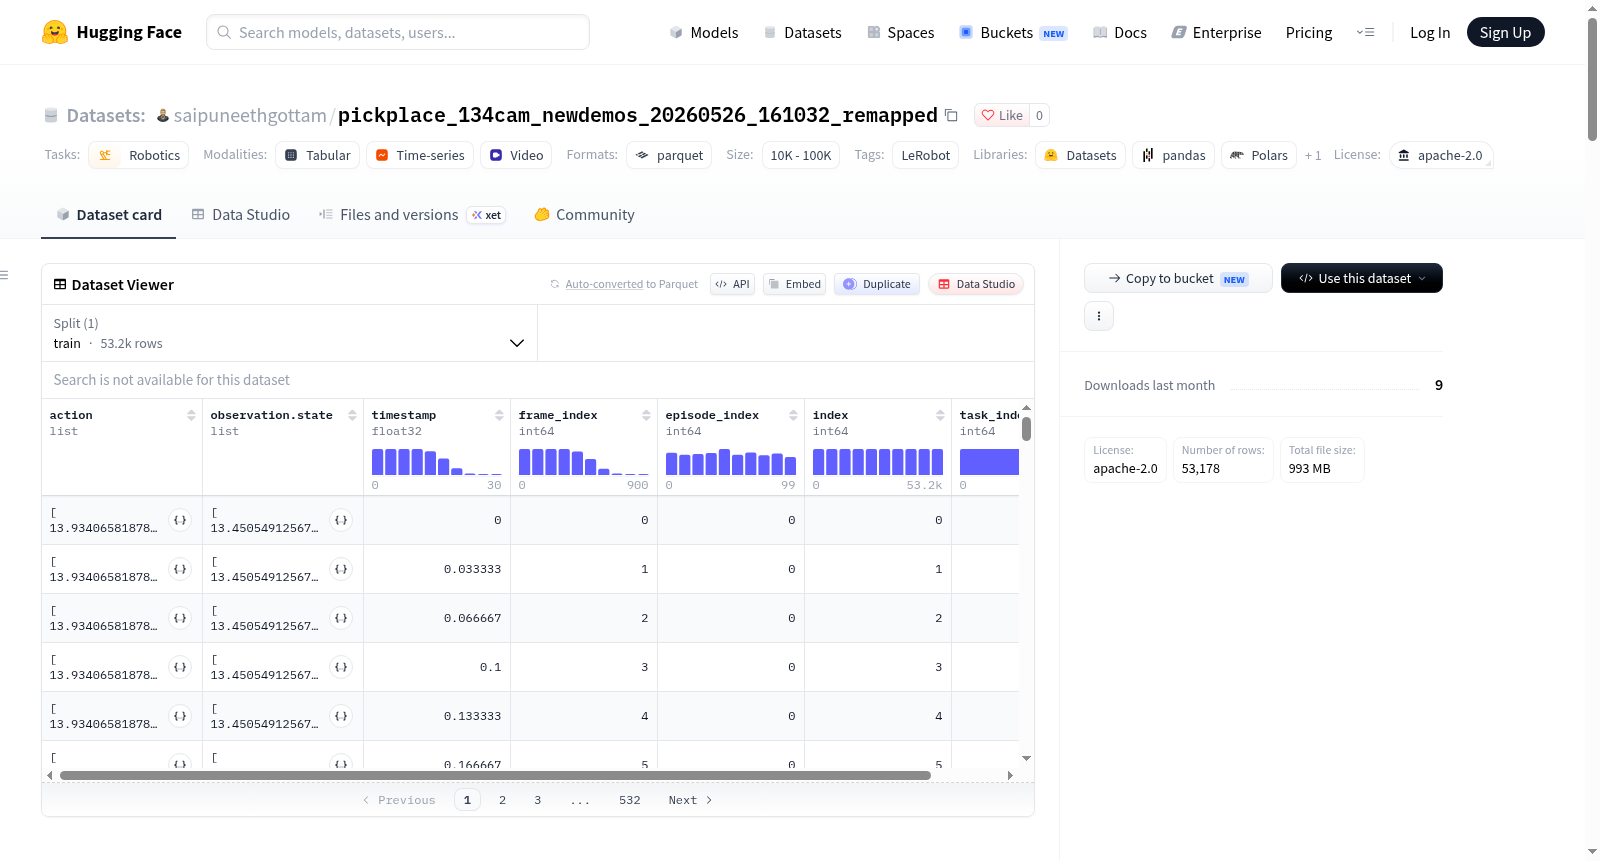
This dataset is designed for robotic pick-and-place tasks, created using the LeRobot tool. It contains 100 training episodes with a total of 53,178 frames at a frame rate of 30fps. The data is stored in parquet format, featuring actions (6 joint positions: shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, gripper), observation images (from three cameras: camera1 and camera2 at 1280x720 resolution, camera3 at 640x480, all RGB videos), observation states (6 joint positions), episode index, frame index, task index, and timestamps. The dataset is tailored for the so_follower robot type, with video files encoded in AV1, total video size of 200MB, and data file size of 100MB.